



UP NEXT
Welche Reinigungsroboter eignen sich für stark verschmutzte Industrieböden?23 září, 2026

30 září, 2026
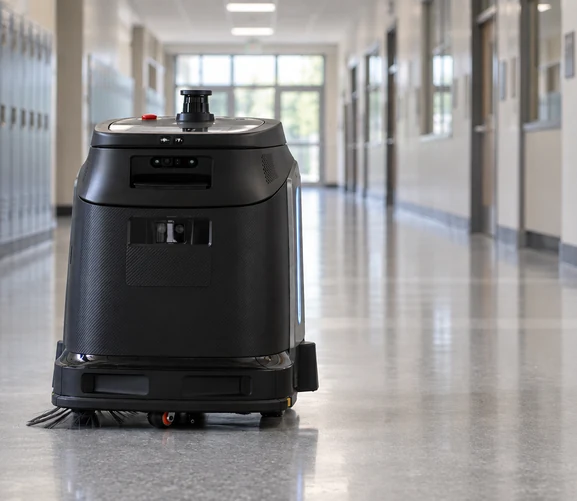
Custodial staff are getting harder to hire, while cafeterias, gyms and corridors still have to be cleaned every day. More schools are using cleaning robots to reduce the manual workload on these routes.
But a campus is not one uniform site. Cafeterias carry mixed wet and dry soil, gyms are large open floor plates, underground parking garages are the largest continuous hard floors on site, corridors have people in them all day, classrooms are dense with furniture, libraries are carpeted, and outdoor walkways keep feeding grit back inside. Floor types, available time slots and access conditions all differ, and one machine rarely covers everything.
This article sets out which campus routes to automate first, which model fits each one, how scheduling works around a timetable, and what changes when a program expands from one building to a whole district.
A robot task runs a continuous route: cafeteria to corridor, commons to gym approach, entrance hall to main circulation. It does not clean isolated rooms.
That matters because the chokepoints are almost always at the boundaries between areas. The door from the cafeteria into the corridor, the turn from the corridor into the gym, the matting and step between the entrance hall and main circulation. Each area looks wide enough on its own; the connected route may not be.
Multi-story teaching blocks add a second issue: routes cross floors.Robots cannot use stairs, so inter-floor cleaning depends on elevator integration. Confirm this during the survey, because otherwise someone has to carry the machine between floors and the automation case falls apart.
Start with the route that is cleaned every day, covers the most floor and is most visible. Expand once it runs reliably.
|
Campus route |
Why start here |
Fit |
Note |
|
Cafeteria and dining hall |
Heavy daily soil, open layout, highly visible |
Very high |
Mixed wet and dry soil, needs sweeping and scrubbing together |
|
Gym and multi-purpose hall |
Large uninterrupted hard floor, few obstacles |
Very high |
Verify wood flooring against the applicable-surface list first
|
|
Underground parking garages and the largest hard floors |
Largest continuous hard floor on campus, cleaned on a fixed route |
High |
Needs long runtime and strong scrubbing pressure |
|
Main corridors and commons |
Predictable traffic, appearance-critical |
High |
Schedule during lessons or after dismissal |
|
Entrance halls |
Source of most soil on campus, especially in wet weather |
High |
Soil is concentrated, suits spot cleaning |
|
Outdoor walkways and plazas |
Leaves and grit keep being carried indoors |
High |
Needs an outdoor machine, specified separately |
|
Library and administration |
Consistent floor area, mostly carpeted |
Moderate |
Needs a carpet machine |
|
Classrooms |
Smaller areas, dense furniture |
Moderate |
Later-phase route, not the pilot |
|
Restrooms and stairs |
Complex geometry, steps |
Low |
Keep manual |
A first deployment at a mid-size school usually starts with one machine on one repeatable hard-floor route that is cleaned every day. That is enough to show the effect on the cleaning workload without making the first rollout complicated.
Model selection follows route width, floor type and available time slot, not the size of the school.
|
Campus route |
Recommended model |
Basis |
|
Cafeteria and dining hall |
Omnie or Mira |
Sweeps and scrubs in one pass; identifies both dry and wet waste |
|
Gym and multi-purpose hall |
Omnie |
Stable localization across large spans, operates in low light |
|
Underground parking garages and the largest hard floors |
Marvel |
Sweeps and scrubs in one pass; 5–10 hours of runtime on one charge |
|
Classrooms, corridors, library hard floors |
Mira |
One-pass cleaning, compact enough for narrow paths |
|
Classrooms and offices with carpet |
Phantas |
Under-table access, covers hard floors and carpet |
|
Inter-floor routes in multi-story blocks |
Phantas |
Takes elevators autonomously |
|
Entrance halls |
Phantas or Omnie, with spot cleaning |
Concentrated soil, handled on detection |
|
Outdoor walkways, plazas, sports surrounds |
Beetle |
Indoor and outdoor sweeping |
|
Library and carpeted areas |
Vacuum 40 |
Scrubbers do not apply to carpet |
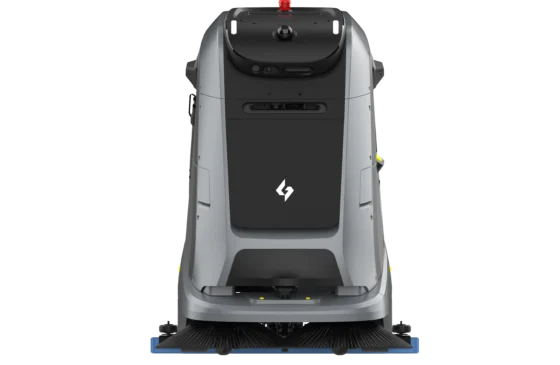
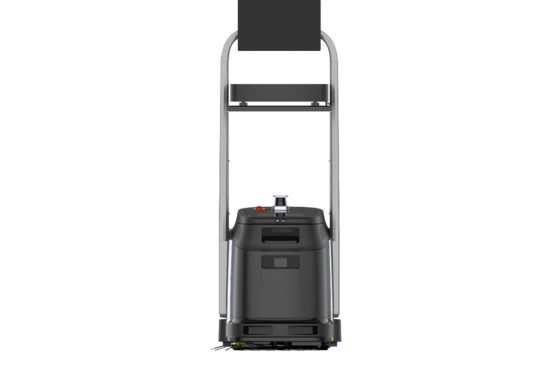
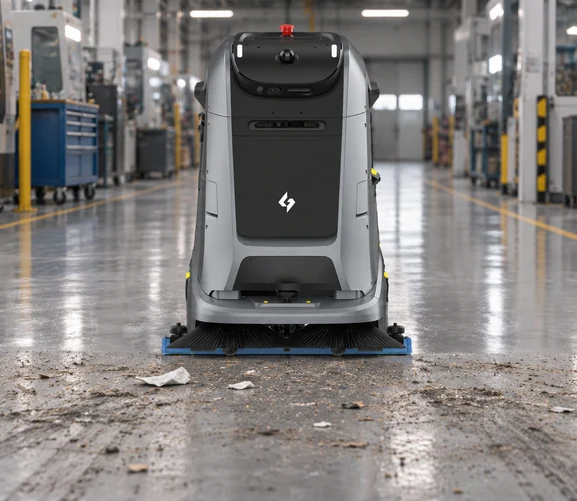
Phantas combines scrubbing, vacuuming, sweeping and dust mopping in one compact unit, covering both hard and soft flooring.
Four things make it suited to campus work. It reaches and cleans under-table areas, which is the main constraint in a classroom. It takes elevators autonomously to perform inter-floor cleaning, so a multi-story block does not need a machine per floor. It runs quietly, without disturbing faculty or students, with noise held within 60 dB in quiet mode. And auto spot cleaning treats detected soil rather than the full route, minimizing water and power consumption. Docking stations extend uptime and reduce the number of times staff need to intervene. The smallest obstacle it recognizes is 20 mm, which covers the bags, bottles and dropped stationery normally found on a school floor.
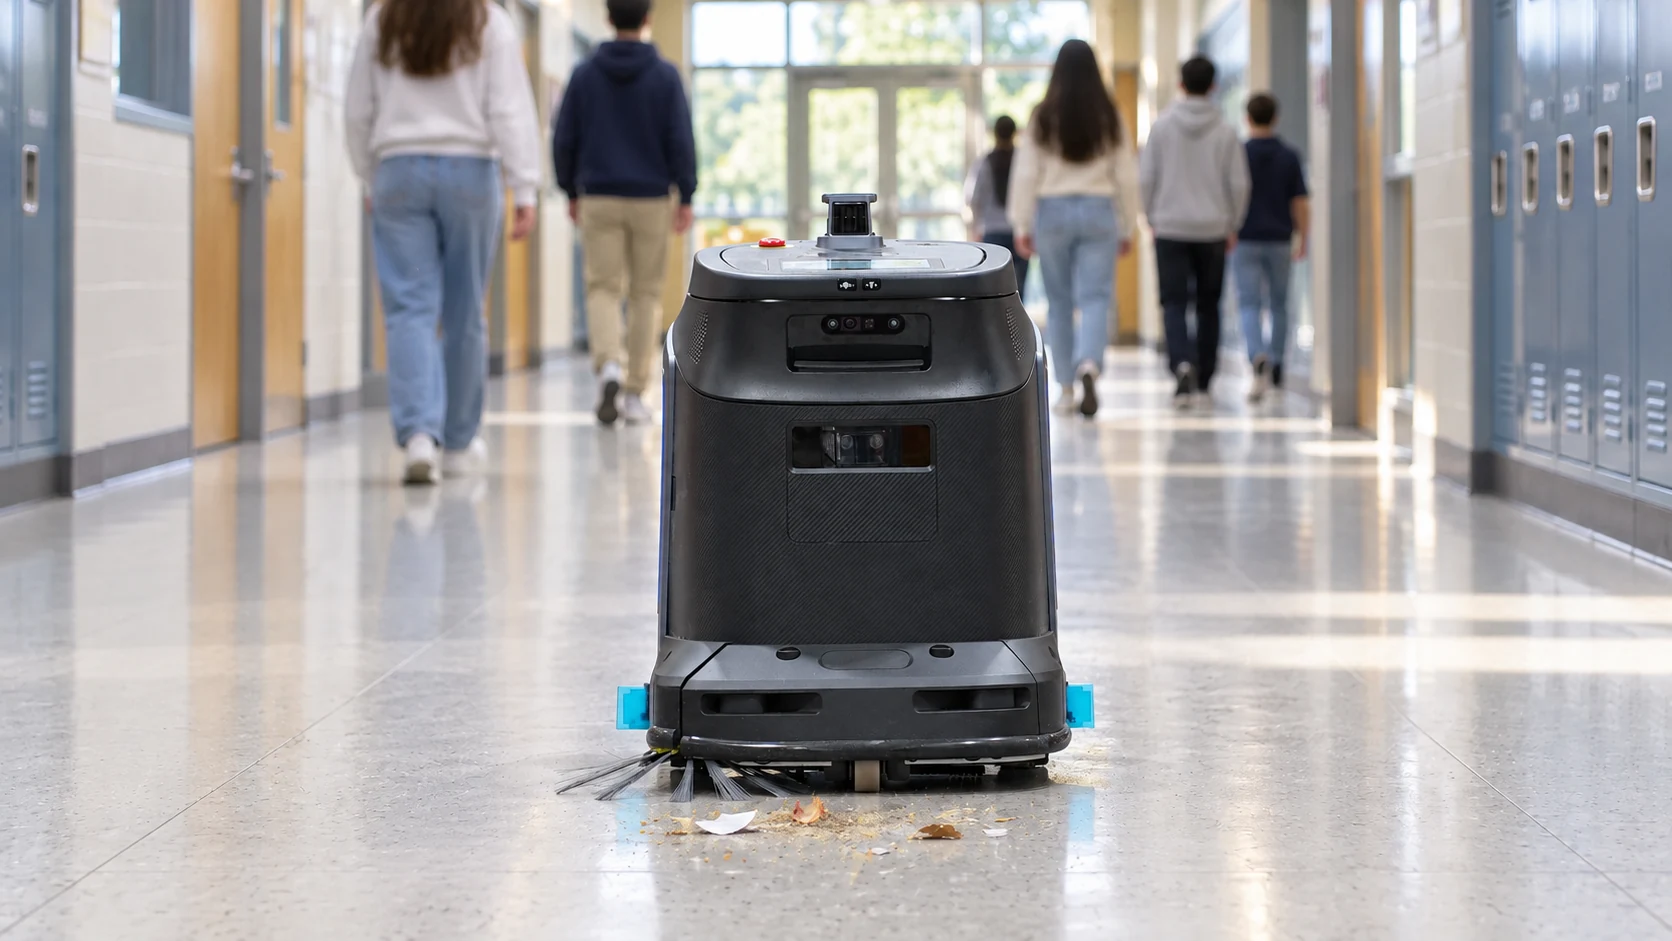
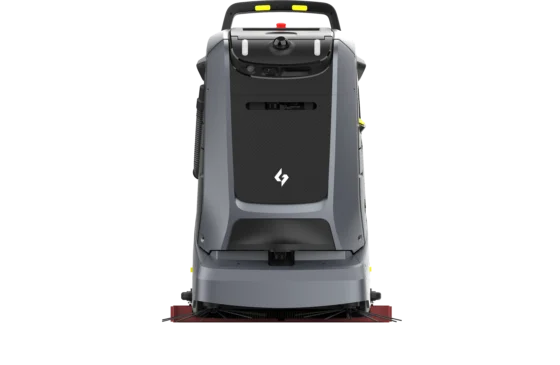
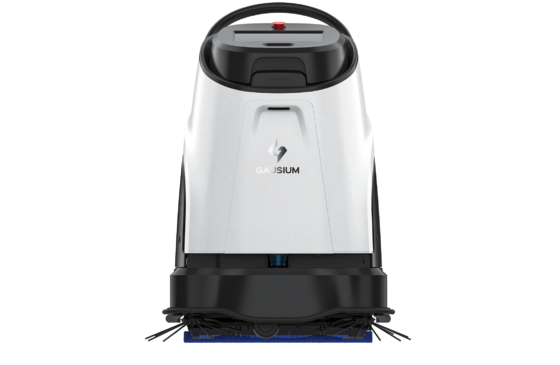
Mira sweeps and scrubs in one pass, and Gausium positions it for classrooms, corridors, libraries and gallery spaces.
Two capabilities matter most on a campus. Drop & Go deployment adapts to changing layouts and temporary event setups without remapping, which suits schools that rearrange rooms several times a term. And a self-cleaning wastewater system reduces the maintenance workload at the end of a shift, supporting continuous autonomous operation.
Its compact body and maneuverability handle narrow pathways and crowded indoor spaces, and it runs quietly enough not to disrupt teaching.
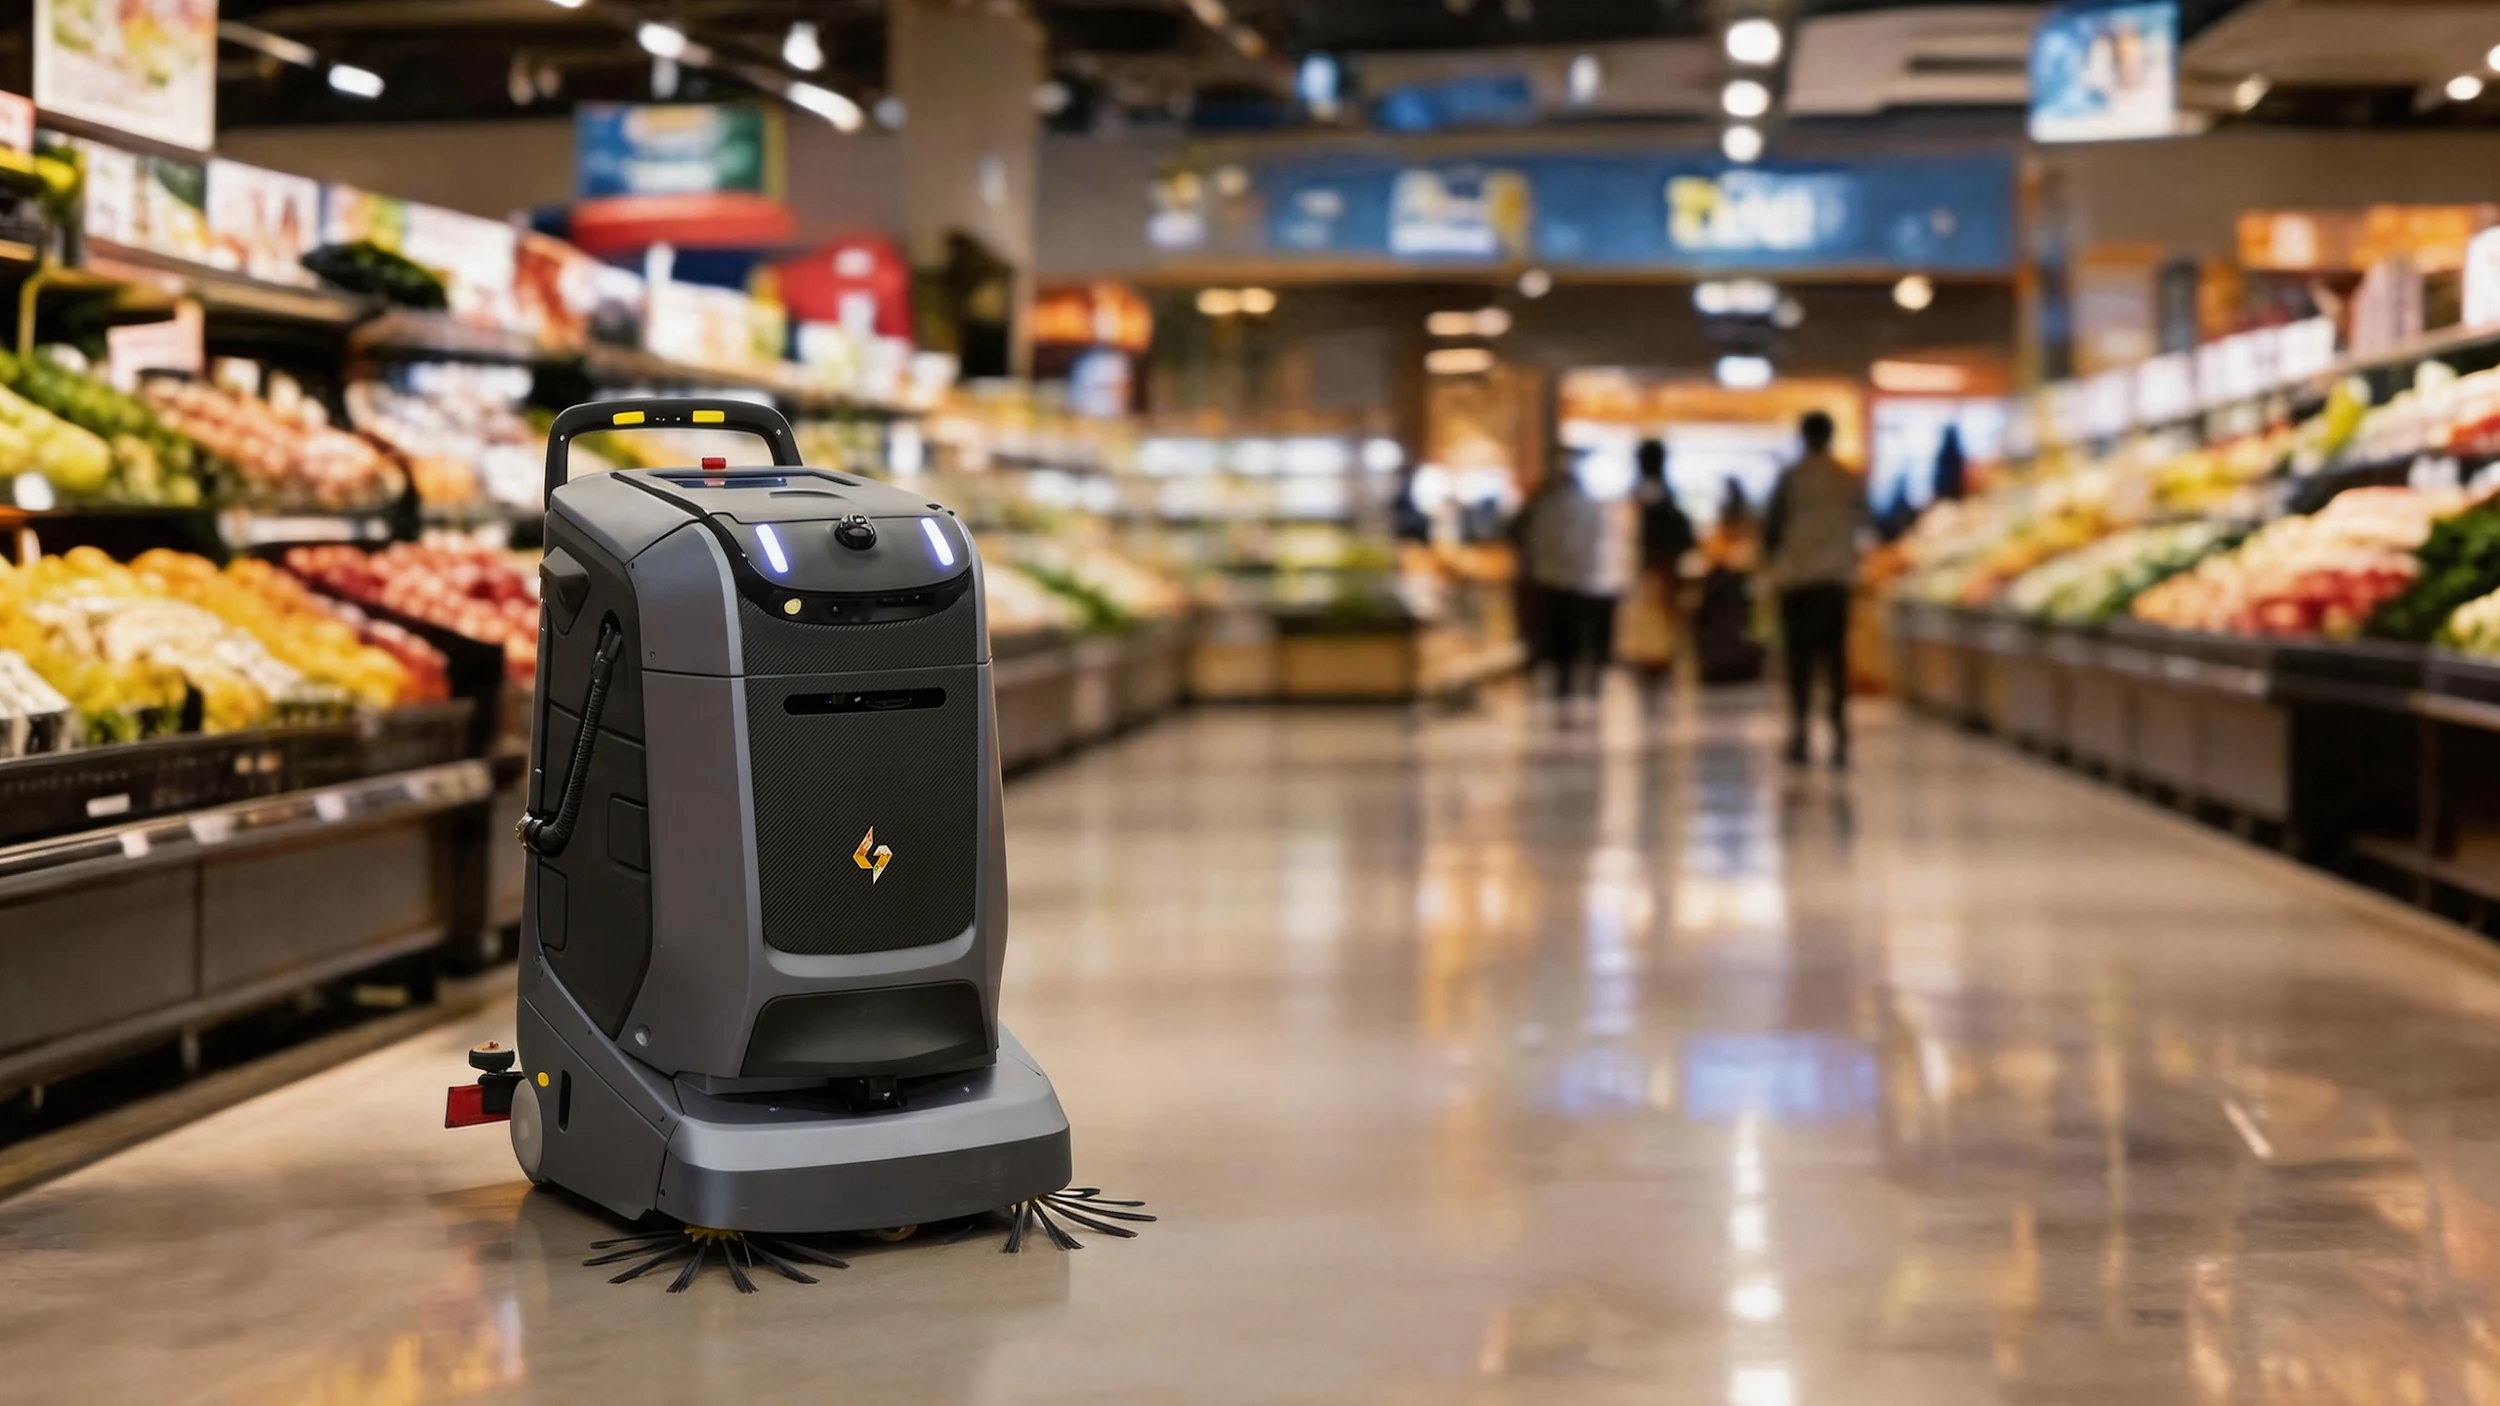
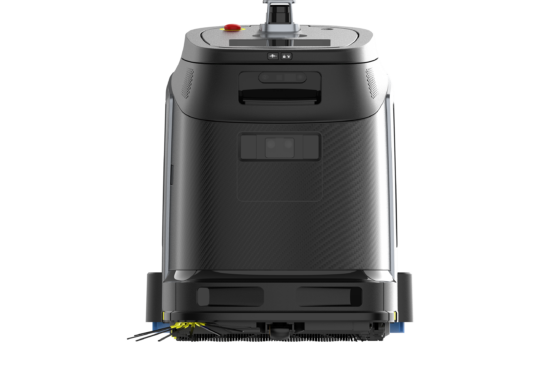
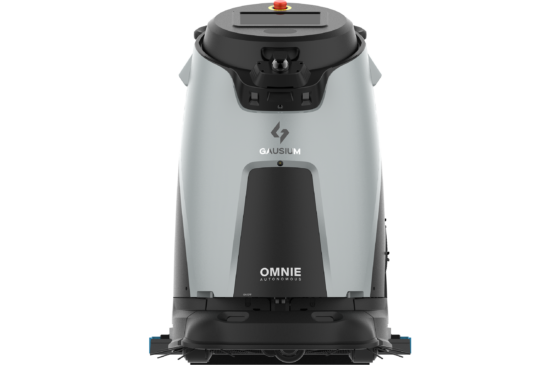
Omnie is built for complex environments with continuous foot traffic, and Gausium positions it for campuses, museums and exhibition halls.
Advanced AI spot cleaning handles scattered debris and liquid spills in high-footfall educational spaces. Intelligent obstacle avoidance navigates safely around students, visitors and changing pedestrian traffic. Robust 3D LiDAR navigation keeps operation stable across large campus spaces, including gyms running on minimal lighting outside activity hours.
Wood-floored halls must be checked against the applicable-surface list rather than assumed.
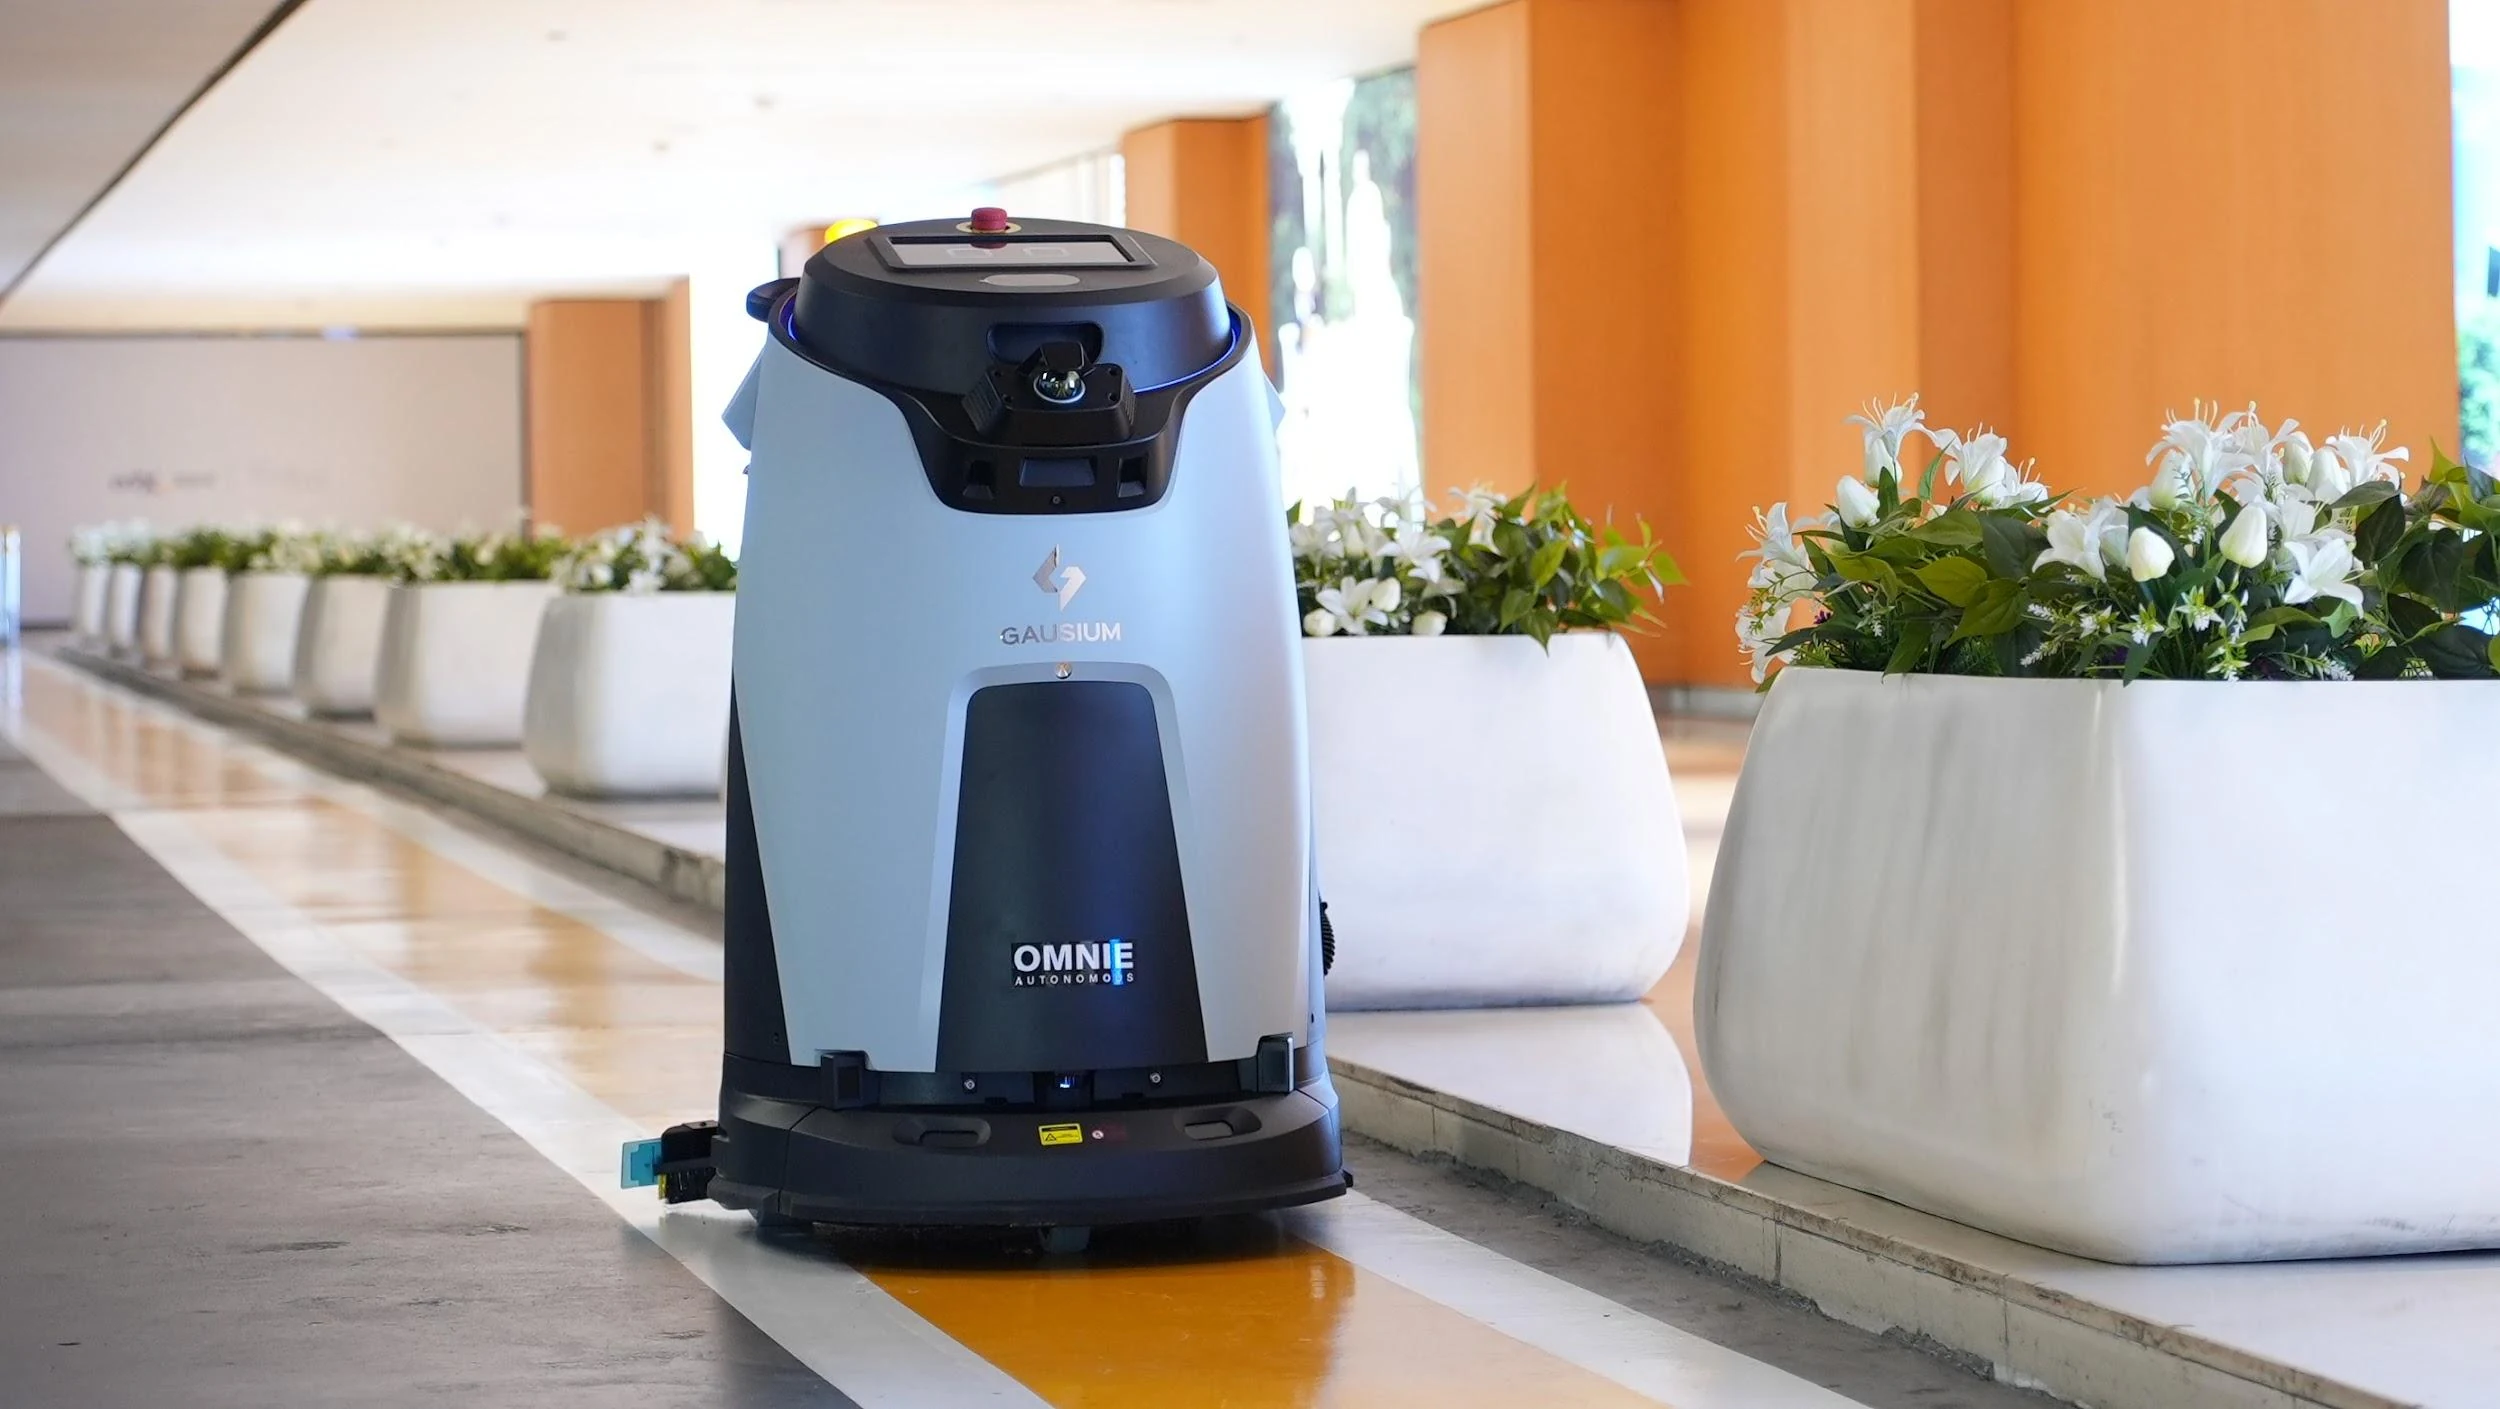
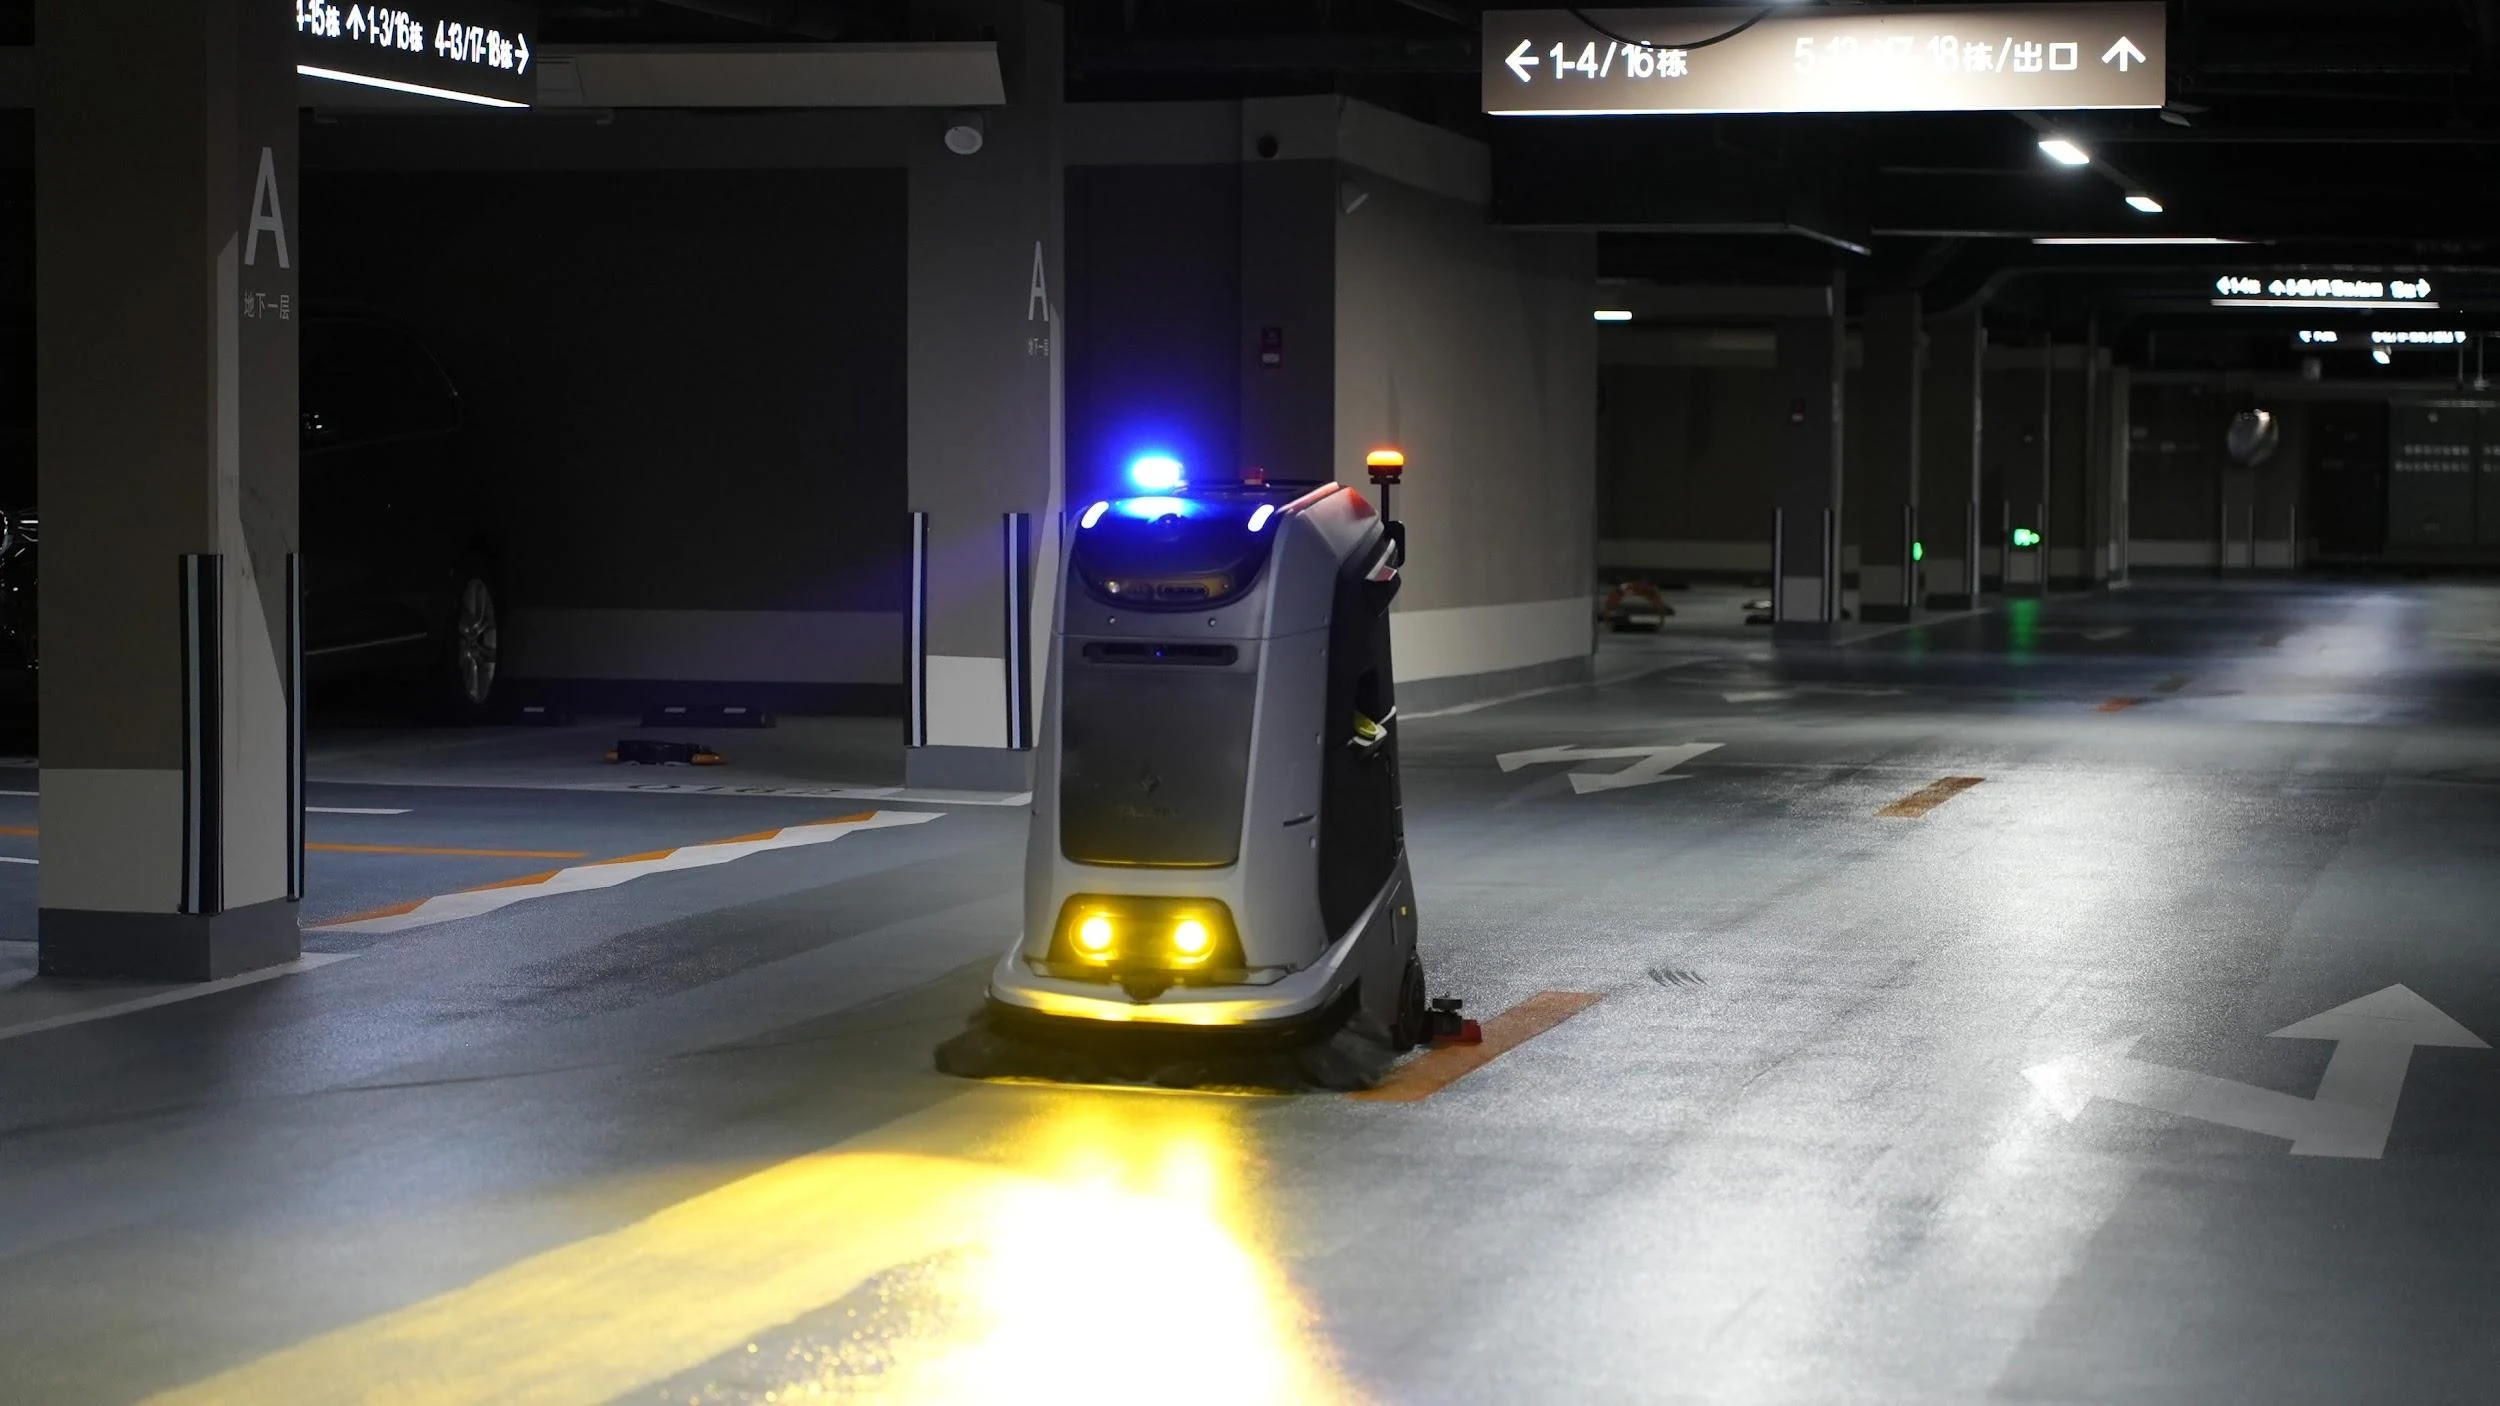
On many campuses, the parking garage is the longest single route on site. Vehicles bring in dry grit and wet residue on their tires, so the floor needs both kinds of soil handled on the same run.
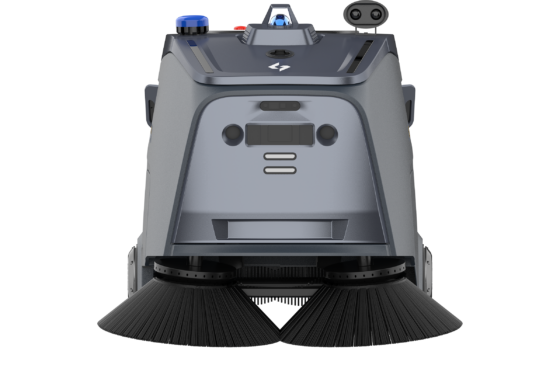
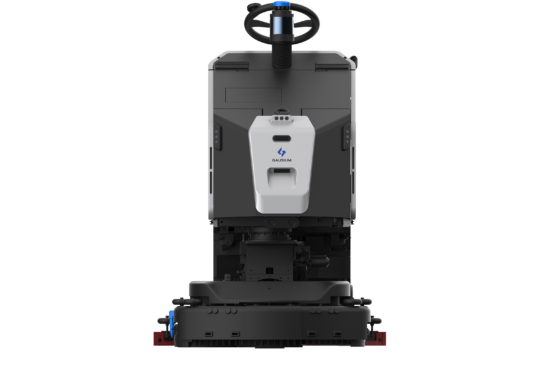
Marvel is the Gausium model for this kind of floor. It combines sweeping and scrubbing, and its capacity is sized for long routes: 80 L of clean water, 70 L for waste water, and 5 to 10 hours of operation per charge. A full-length route therefore needs fewer stops to refill, empty or recharge.
Timing follows the same logic as the corridors. Run the garage route during lessons, when vehicles are rarely moving in or out, and keep it clear of the morning arrival and afternoon dismissal peaks.
Marvel uses the same self-cleaning design as Mira, so once the task ends, there is little left for the caretaker to rinse or empty.
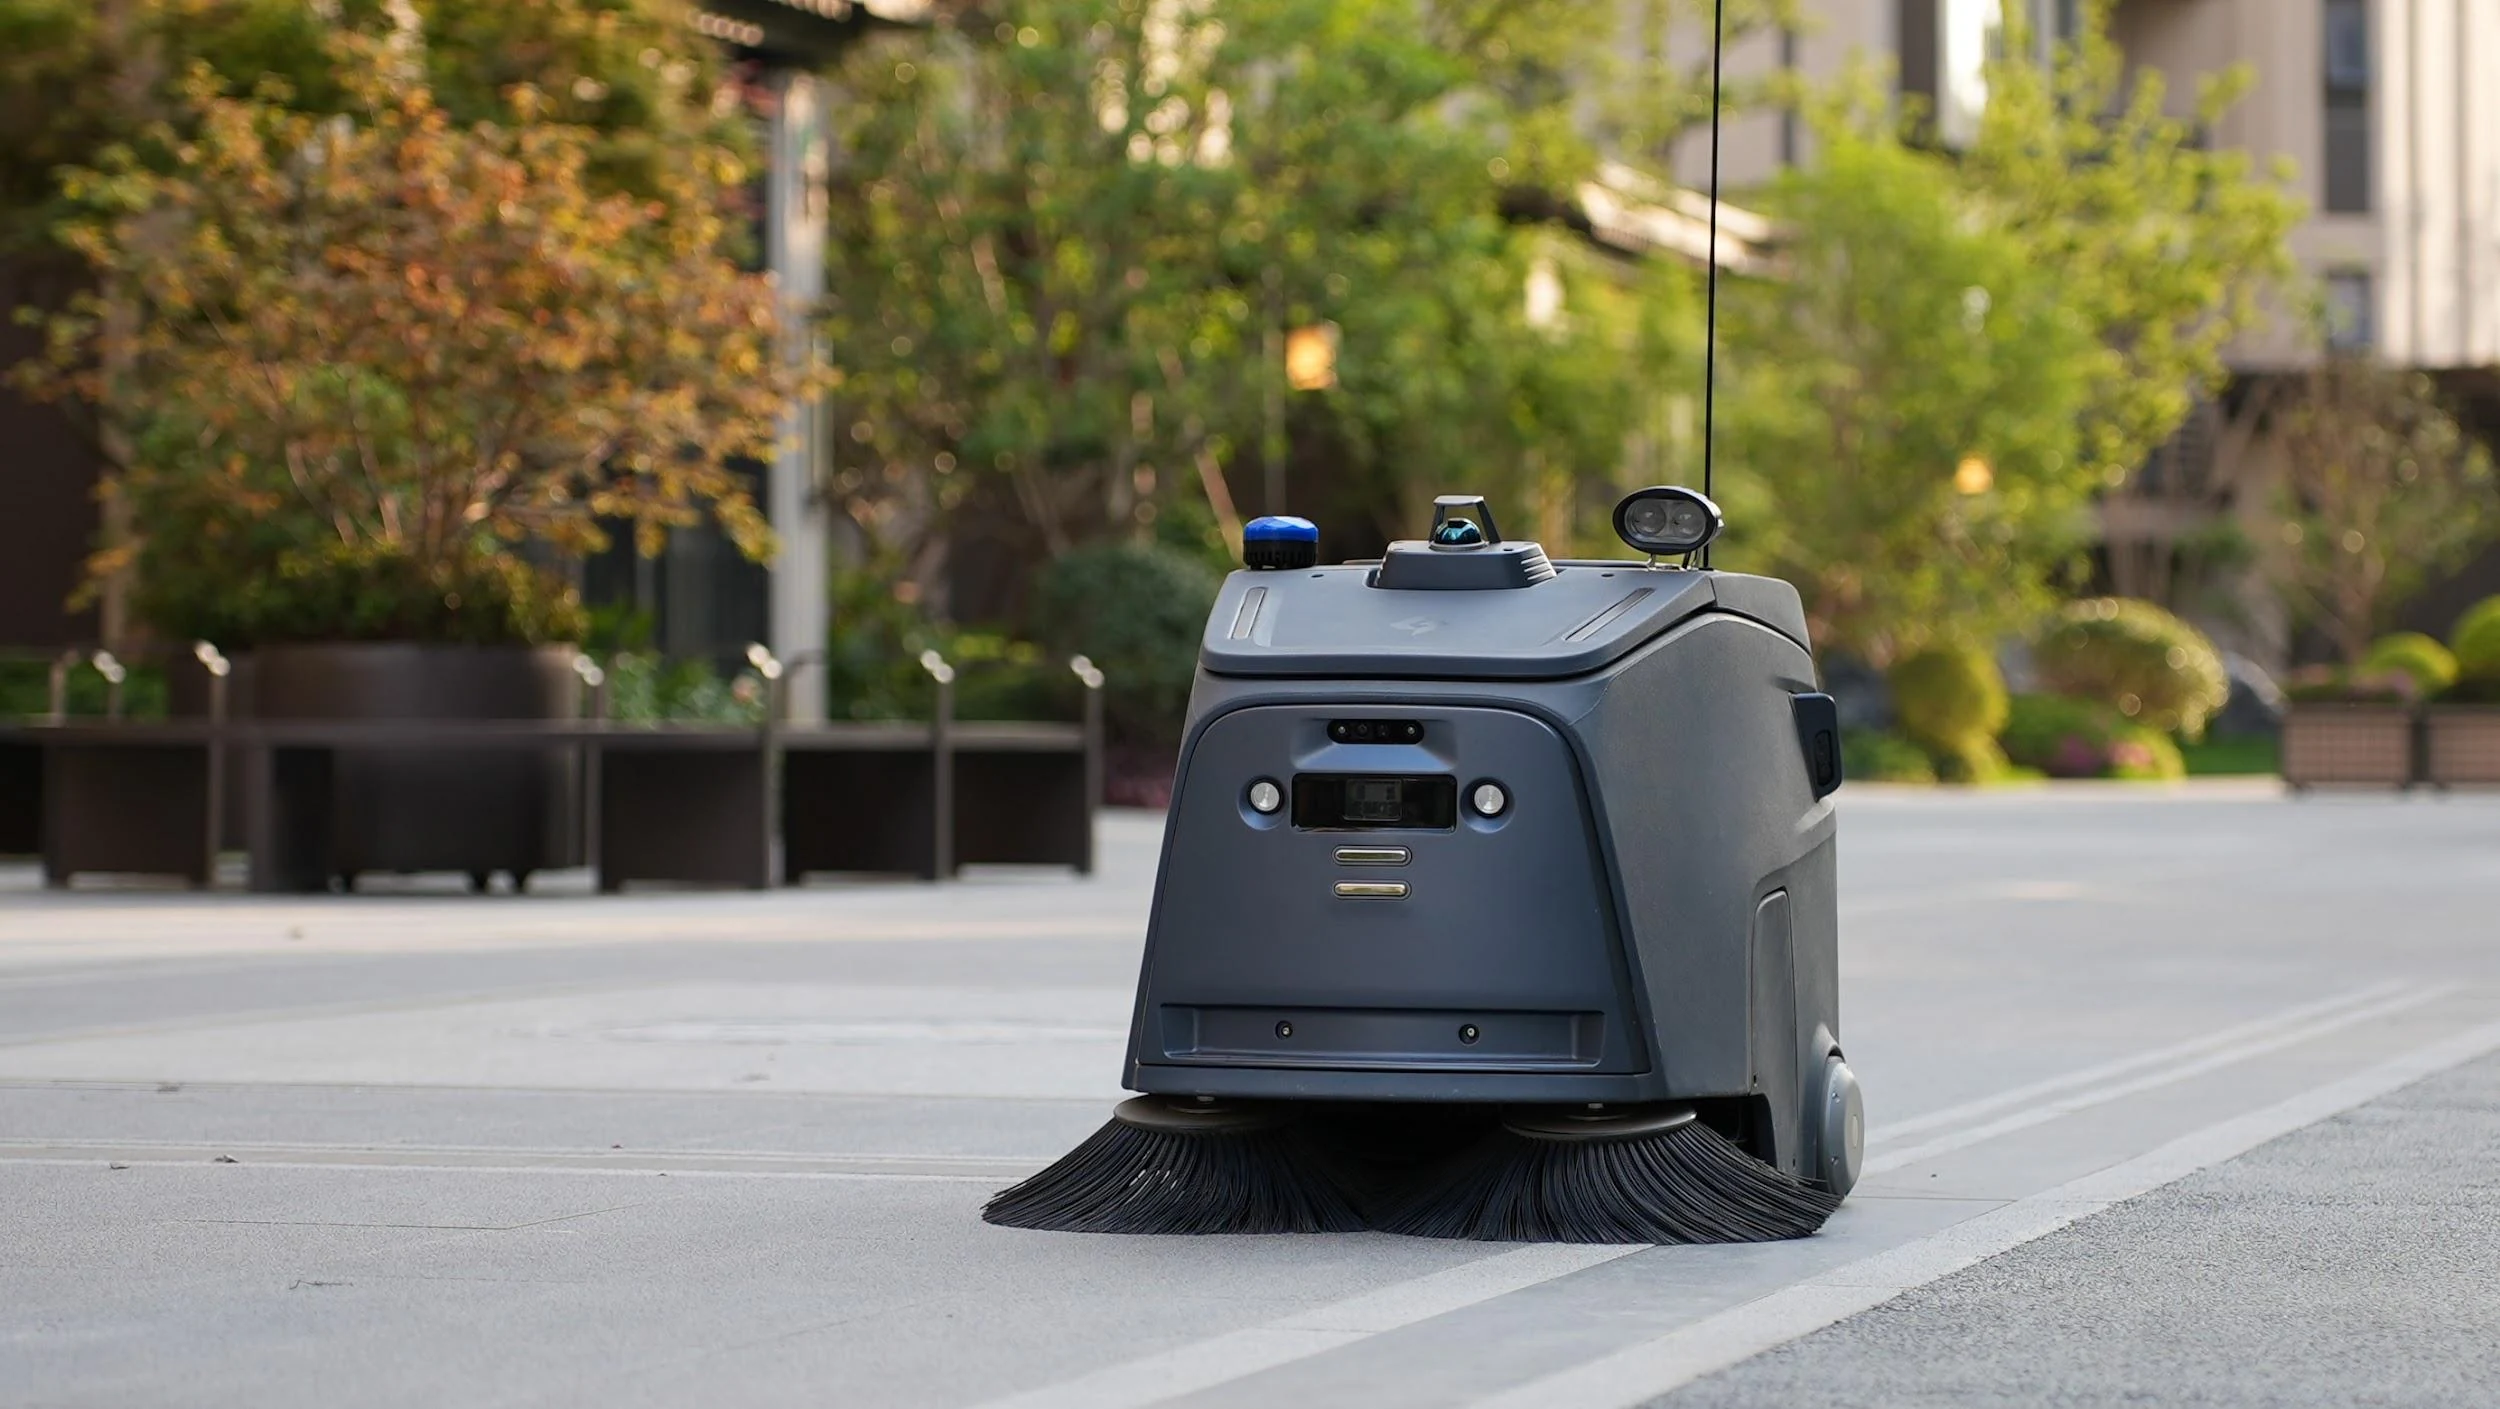
Leaves and grit from outdoor areas are carried indoors continuously, so cleaning only inside means repeating the same work. Beetle sweeps both indoors and outdoors, with strong absorption across fine dust, debris and large-size waste, zero-distance edge cleaning, and dust control that prevents particles becoming airborne during operation.
Beetle sweeps and does not scrub. Confirm the specific outdoor surface against its applicable-surface list.
Libraries, reading rooms and parts of administration are carpeted, where scrubbers do not apply. Vacuum 40 is a vacuuming specialist for all sorts of carpet tiles, with H13 medical-grade air purifying capability and quiet operation that does not disturb faculty or students. Purifying, humidifying and aroma diffusion are available as options.
Gausium robots are already running in education settings:
Further deployments are listed in the case study library, and the education solution page covers the wider product set for campuses.
The same machine produces different results depending on when it runs. On a campus, the available time is broken up by the timetable.
Schedule against the timetable, not the clock. Match tasks to the actual gaps in the teaching schedule rather than fixing a time. Timetables change every term, so the school needs to be able to adjust routes itself. Mapping and map editing run through the mobile app, with no professionals or external tools required.
Lesson time is the best window for corridors. The few minutes between lessons carry the heaviest foot traffic and are the worst time to run. During lessons, corridors are almost empty. This is the opposite of most commercial sites.
Cafeterias run straight after each sitting, not at the end of the day.
Events and exams are handled by Drop & Go. Hall setups and exam layouts change the floor. A machine supporting Drop & Go continues without remapping.
Term time and school breaks are two different programs. Term time is maintenance cleaning; breaks are for deep cleaning and floor restoration. Be clear which one the evaluation covers.
A multi-site program is an operations project, not a single equipment purchase. Prove one thing per stage before moving on.
|
Stage |
What to prove |
What to decide next |
|
One pilot building |
Whether one machine completes the cafeteria, gym or corridor route inside the available window with little intervention |
Model, cleaning window, operating routine, record format |
|
5–10 similar schools |
Whether the same route standard and training package transfer directly |
Which model becomes standard for that route family |
|
20+ schools |
Whether facilities leadership can see task completion across sites in one place |
Fleet reporting, consumable planning, fault escalation path |
|
District-wide |
Whether route updates keep pace with term changes, events and break-time works |
Named route owner and update cadence per school |
Group by route family rather than by school count. Most districts have repeatable building patterns: primary cafeterias, middle-school commons, high-school gyms, administration blocks. One model per route family is what keeps a fleet manageable.
|
Task |
Owner |
Reason |
|
Large repeatable floor routes |
Robot |
Fixed route, daily, largest share of the area |
|
Restroom cleaning and replenishment |
Staff |
Requires inspection and detail work |
|
Classroom touchpoints and waste |
Staff |
High variability, dense furniture |
|
Spill response and event reset |
Staff |
Needs immediate action |
|
Stairs and steps |
Staff |
Outside machine coverage |
|
Route records and completion data |
Robot + cloud platform |
Digital logs are easier to verify than paper checklists |
To arrange a route survey and model configuration for a specific campus, contact Gausium.
Schools rarely have technical staff on site, so whether caretaking teams can handle upkeep unaided decides whether the program holds.
Starting tasks, emptying the bin and replacing brushes and squeegee blades are routine operations that need no technical training. Have a caretaker complete each one unaided during the trial. Consumable status is visible through the cloud platform, where task completion across multiple schools appears in one place, so supervisors do not need to visit each site.
For faults, the Gausium Remote Maintenance Center provides cloud diagnostics and troubleshooting 24/7. For a school with no technician on site, remote diagnosis is often the first line of support.
Usually not. Cafeterias, gyms, classrooms, libraries and outdoor areas differ in floor type, area and available time slots. Most schools assign two or three machines by route, for example Omnie for the cafeteria, Phantas for classrooms and Marvel for an underground parking garage, all managed on one platform.
The cafeteria or the gym. Both are cleaned daily, cover the most floor, are the most visible, and show results clearly during a pilot.
Not by stairs, but Phantas takes elevators autonomously to perform inter-floor cleaning. Confirm the elevator integration requirements during the survey.
Phantas and Mira both run quietly, and Phantas holds noise within 60 dB in quiet mode. Confirm on site during the trial.
Check the specific floor against the model’s applicable-surface list rather than assuming. Confirm the hall’s flooring with Gausium before selection.
Scrubbers do not apply to carpet. Vacuum 40 covers all sorts of carpet tiles and includes H13 medical-grade air purifying capability.
Mira supports Drop & Go deployment and continues without remapping. On other models, map editing is handled by the school through the mobile app.
Group by route family, standardize one model per family, then expand by building type or region. Fleet reporting, consumable planning and a fault escalation path should be in place before reaching 20 sites.
Step 1/2
Please select the type of business you’d like to have with Gausium.
Choose one item from the list
Step 2/2
Thanks for sharing your preference. Please fill out the form below, and we’ll get in touch shortly.
By clicking “Submit”, I authorize Gausium to contact me. Privacy Policy.
Thank you for filling out the form
By clicking “Submit”, I authorize Gausium to contact me. Privacy Policy.